Balance Robot v1
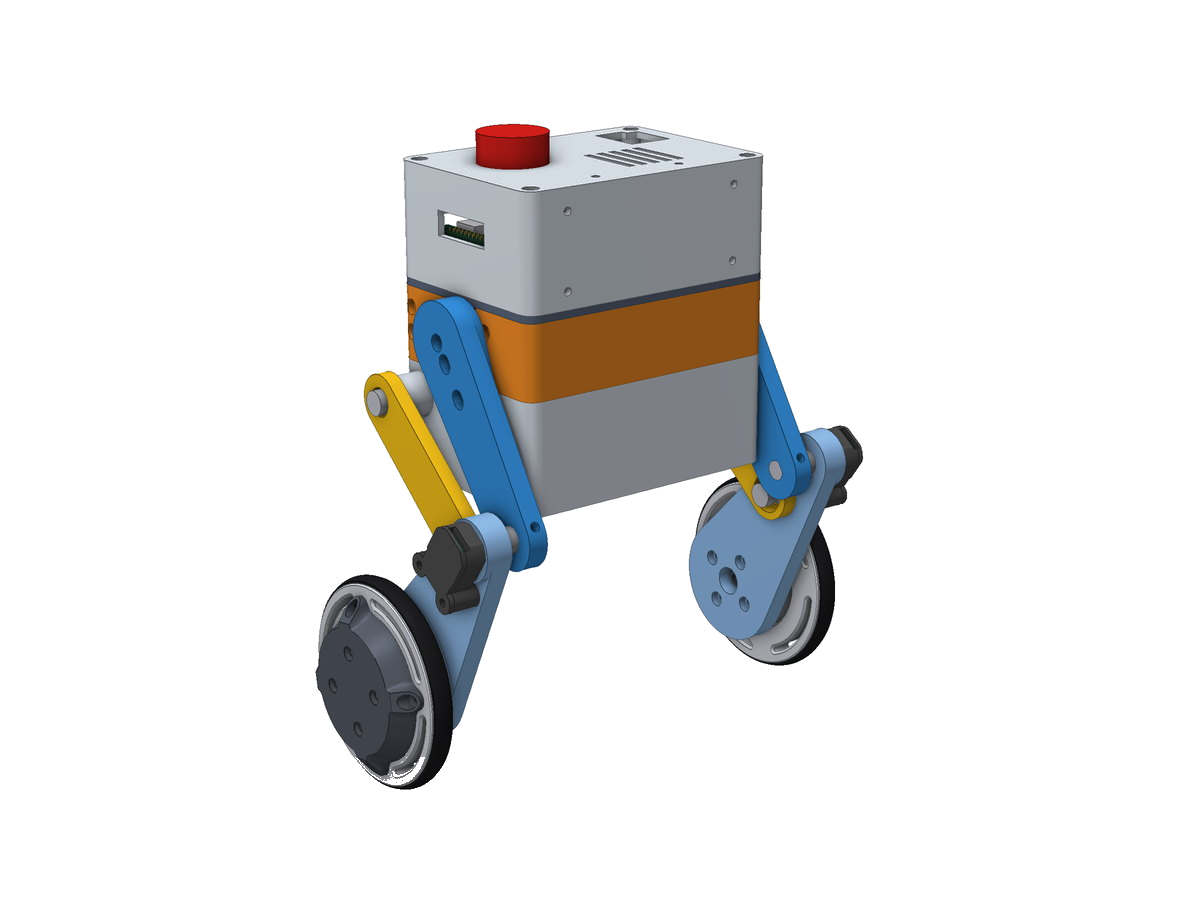
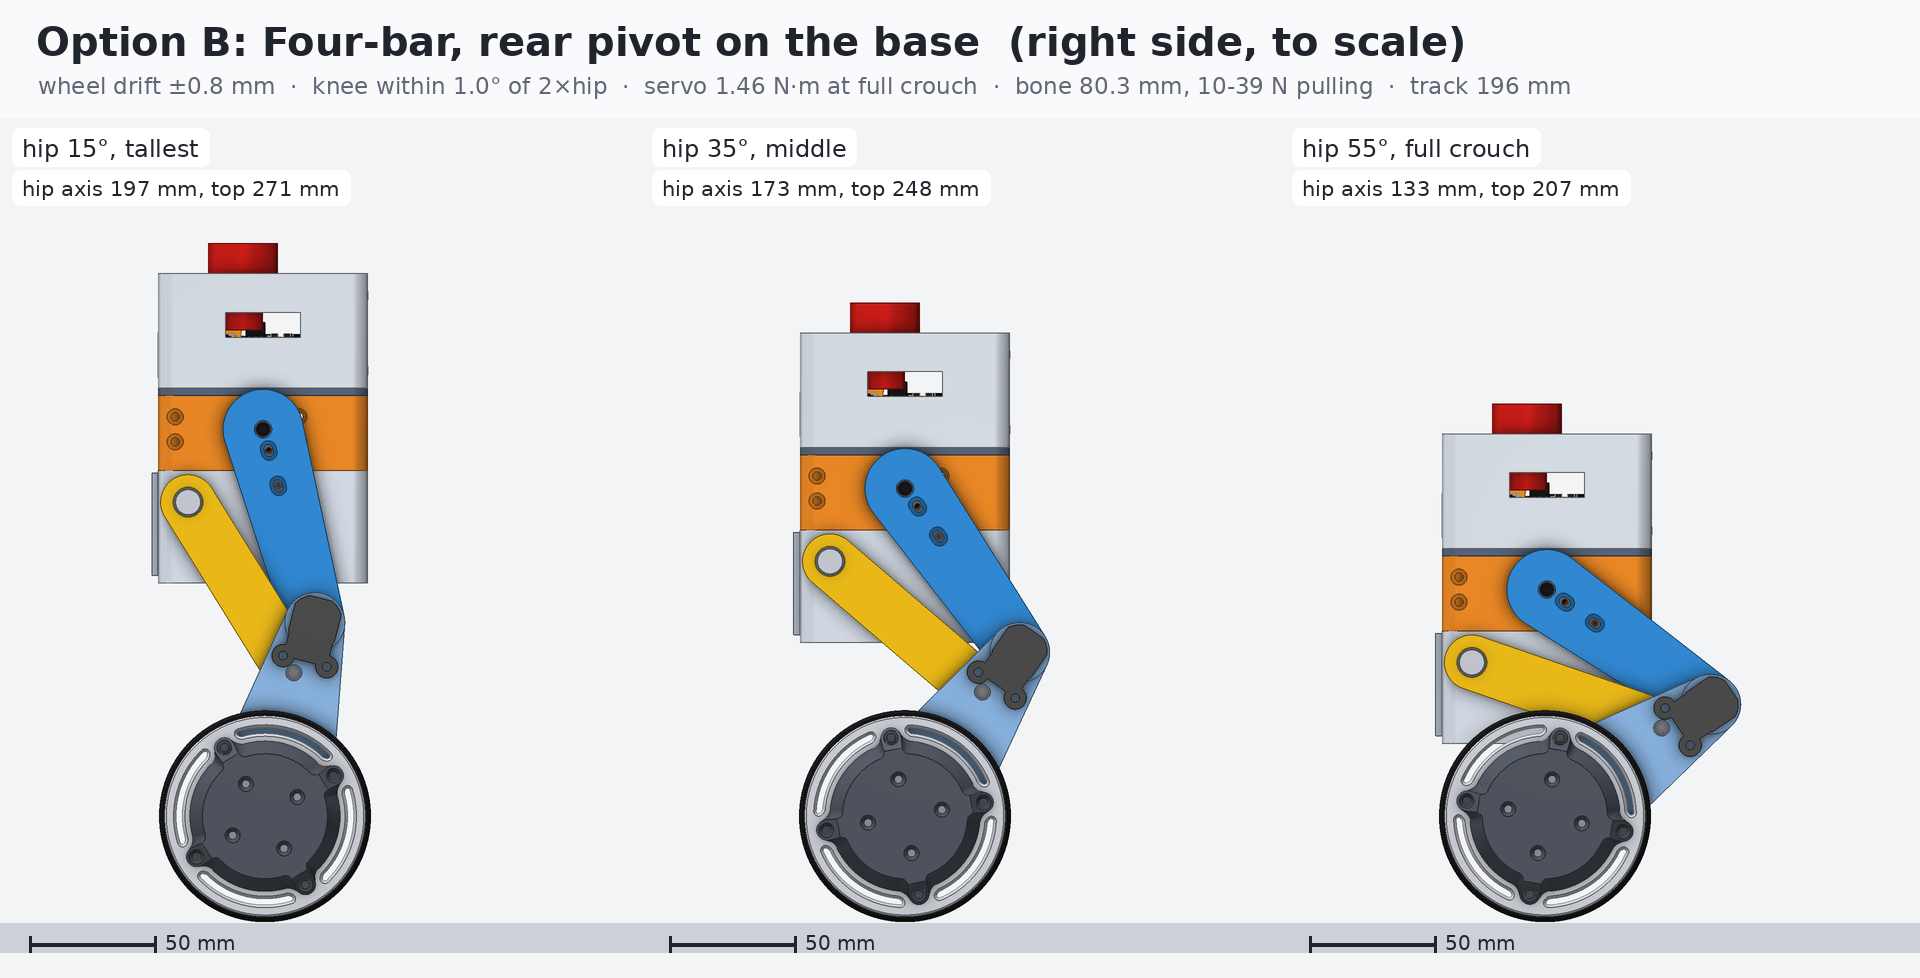
Prototype buildA wheeled biped with four-bar legs. One hip servo per leg sets the height and the wheel stays under the hip; two direct-drive brushless motors keep it upright.
- Four-bar leg: wheel within 0.8 mm of under the hip, 15–55° hip range
- GM4108H gimbal motors with field-oriented control, no gearbox backlash
- 3D-printed body (PLA/PETG), 4S LiPo, top-mounted E-stop
- URDF, ROS 2 description and Isaac Lab tasks generated from the CAD